mowlark
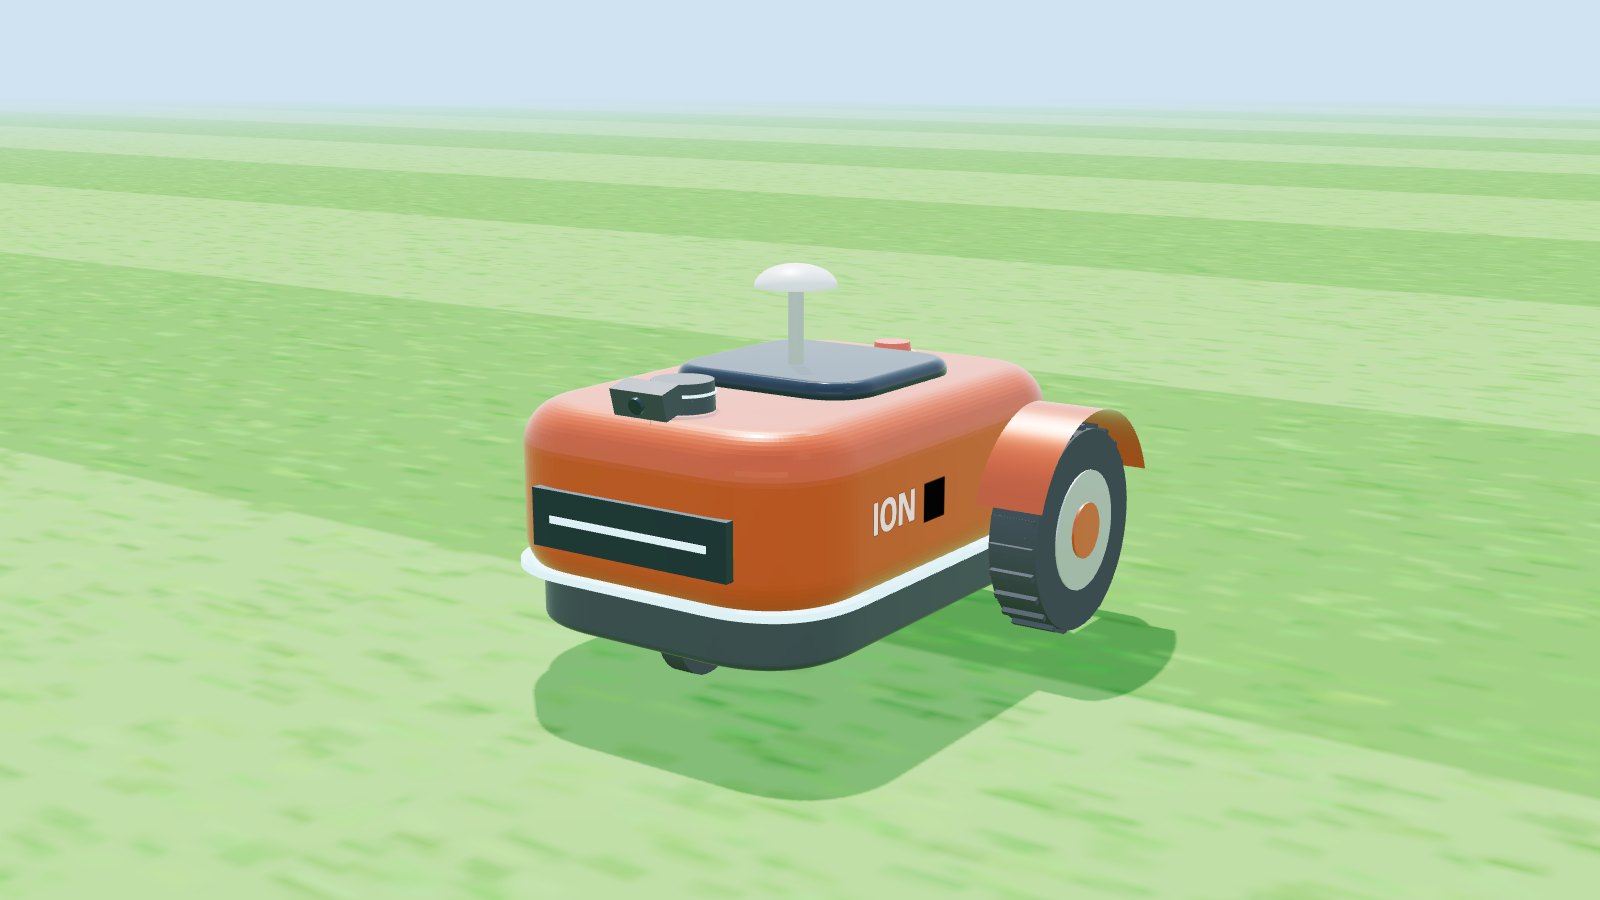
3D render of Ion on a lawn

Ion

The one we're building first.

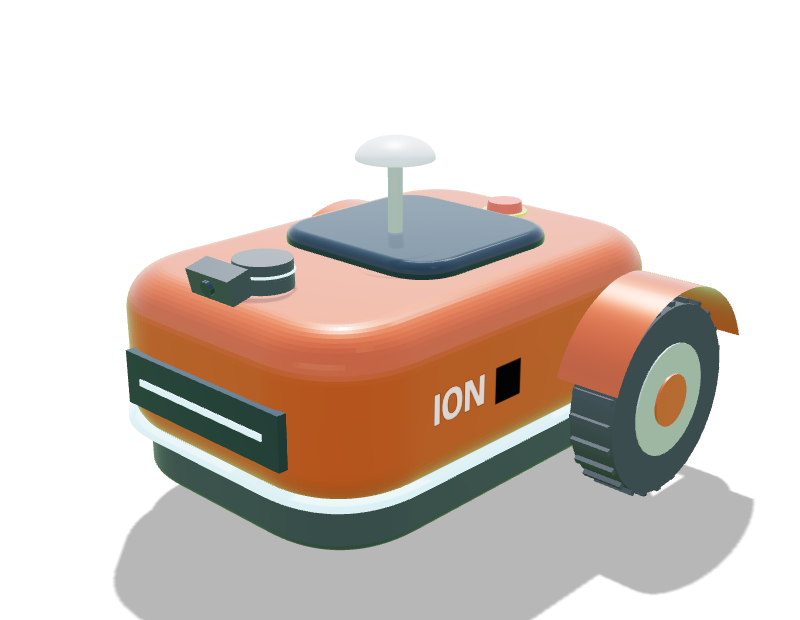
GEN 1 17kg 3D render of Ion

Ion

All-rounder

The one we're building first.

Building firstTwo-wheel differential, 1 caster
  • Cut36 cm
  • Top speed0.50 m/s
  • Peak rate648 m²/h
  • Range500 m²
  • Climb15°
  • Agility115 cm turn
  • Sight47 cm blind
  • Cost≈ $2.2k

Special Factory body: a certified blade guard, battery and dock, so it can be built first.

Weakness A 36 cm cut: big lawns take a long time.

✔ Smoke test passed · 99.0%Full specs →

Gen 1 · All-rounder · In simulation now. First to be built (goal 3).

A rear-drive mower the size of a YardForce Classic 500, which it's modelled on. The real Ion is a used YardForce with its control board swapped for an OpenMower kit, our Raspberry Pi brain, centimetre GPS and a 3D lidar. The body, blade guard, battery and dock are the factory's, already certified, which is why it goes first.

Ion is in simulation and next to be built. Parts and prices are estimates, in US dollars (Nov 2026). Drawings are generated from the profile the simulator uses.

Body (L × W × H)61 × 60 × 35 cm
Mass≈ 17 kg
DriveTwo-wheel differential, 1 caster, 24 cm wheels, up to 0.5 m/s
Blades36 cm → 36 cm cut
Battery7S 6 Ah ≈ 151 Wh
Stripe spacing32.4 cm (10% overlap)
Edge lap35 cm from the edge; uncut band ≈ 17 cm for the trimmer
Turning in place sweepsa 115 cm circle
3D lidar blind zone47 cm ahead of the nose
Margin at raised beds45 cm
Best forSmall and medium lawns (up to ~600 m²) on gentle ground.
Slopesup to ≈ 15°

Drawings

◆ 3D lidar○ RTK GNSS antenna+ turning centre- - - blades
61 cm long × 60 cm wide
From above, nose to the right. Dashed blue: the circle the body sweeps turning in place round the + (its turning centre). Green band: the cut.
blind 47 cm35 cm tall
From the side. Dotted blue: the 3D lidar's lowest beam; anything 4 cm tall closer than that is unseen, so the stop field never shrinks below it.

Parts list

PartWhat it doesPriceSource
Used YardForce Classic 500 robot mowerBody, wheels, motors, blade guard, battery and dock≈ $340used listings
OpenMower v1 board kit (or v2)Drives the motors, reads the mower's sensors≈ $250–340devops.care
Raspberry Pi 5 8 GB + SSD + coolerThe brain≈ $215–245Raspberry Pi list price
simpleRTK2B GNSS + antennaCentimetre positioning≈ $235ArduSimple
BNO085 IMUHeading and tilt$30Adafruit
Livox Mid-360 3D lidarSeeing obstacles$979list price
Pico 2 + safety parts (stop button, relay, wiring)The hardware blade interlock≈ $100estimate
Total≈ $2,149–2,269

Build plan

  1. Sensors on a cartPi, GNSS and IMU on a push-cart; map the lawn's edge by walking it.Test: Static RTK fix within 2 cm for 10 minutes
  2. Board swapReplace the YardForce board with the OpenMower kit; blade motor unplugged.Test: Wheels turn on command; stop button cuts them
  3. Brain inMount the Pi, GNSS mast, IMU and lidar; run the same ROS 2 stack as the sim.Test: Drives a 2 m square and returns within 5 cm
  4. Map and dockRecord the lawn and keep-outs; dock and charge.Test: Ten dockings in a row
  5. Mow, blade offFull missions with the blade disconnected.Test: Coverage report ≥ 95%
  6. Blade onOnly after every check in hardware/safety.md passes; supervised first.Test: Interlock tests pass