mowlark
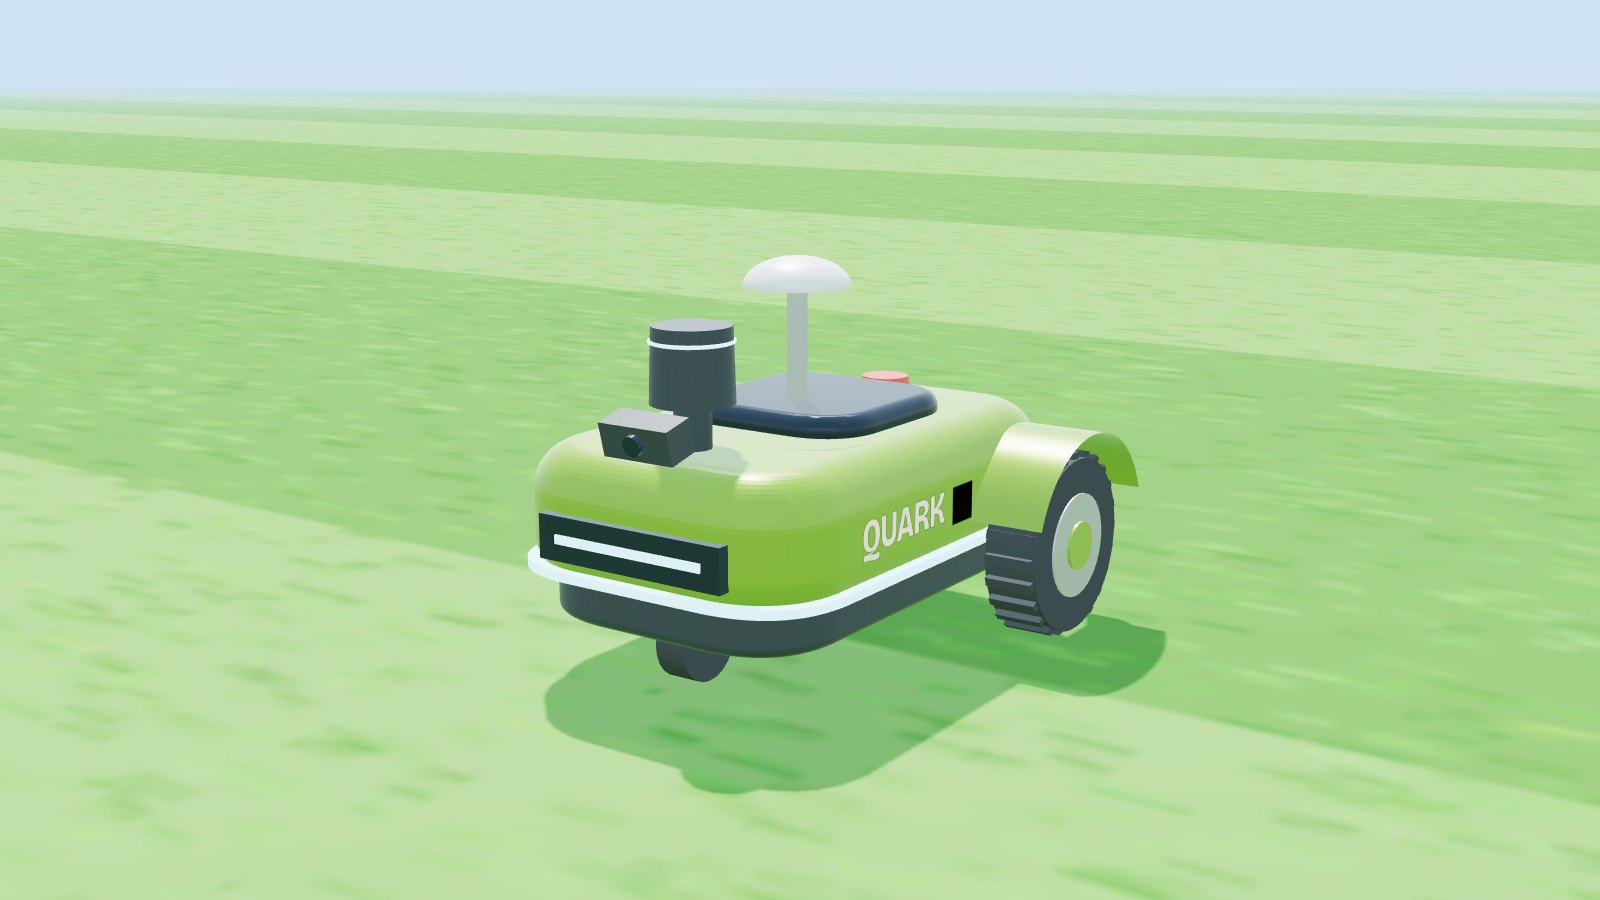
3D render of Quark on a lawn

Quark

Small enough for the side passage.

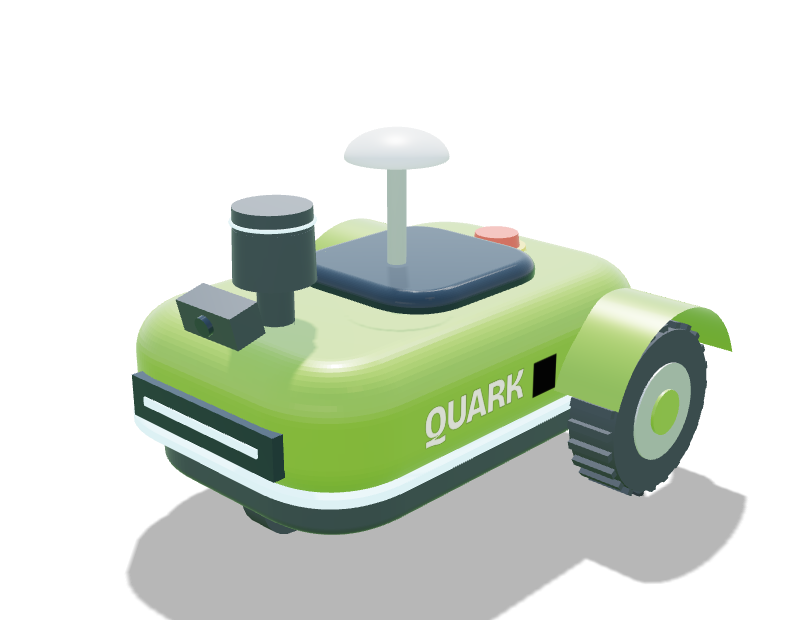
GEN 2 7kg 3D render of Quark

Quark

Scout

Small enough for the side passage.

Concept · simulatedTwo-wheel differential, 1 caster
  • Cut24 cm
  • Top speed0.40 m/s
  • Peak rate346 m²/h
  • Range200 m²
  • Climb12°
  • Agility87 cm turn
  • Sight41 cm blind
  • Cost≈ $1.9k

Special Fits a 55 cm side passage. The lightest and cheapest of the six.

Weakness 24 cm cut, small battery, gentle slopes only.

✔ Smoke test passed · 98.9%Full specs →

Gen 2 · Scout · Concept. Simulated.

A 46 × 42 cm robot with a 24 cm blade for small city lawns and the narrow side passages bigger robots can't get through. It fits through a 55 cm gap. Its own small body is 3D-printed or moulded, with two geared wheel motors, a caster, and the same brain and sensors as every Mowlark.

Quark is a concept: simulated, not built. Parts and prices are estimates, in US dollars (Nov 2026). Drawings are generated from the profile the simulator uses.

Body (L × W × H)46 × 42 × 30 cm
Mass≈ 7 kg
DriveTwo-wheel differential, 1 caster, 16 cm wheels, up to 0.4 m/s
Blades24 cm → 24 cm cut
Battery5S 4 Ah ≈ 72 Wh
Stripe spacing21.6 cm (10% overlap)
Edge lap26 cm from the edge; uncut band ≈ 14 cm for the trimmer
Turning in place sweepsa 87 cm circle
3D lidar blind zone41 cm ahead of the nose
Margin at raised beds40 cm
Best forLawns under ~250 m², passages from 55 cm wide.
Slopesup to ≈ 12°

Drawings

◆ 3D lidar○ RTK GNSS antenna+ turning centre- - - blades
46 cm long × 42 cm wide
From above, nose to the right. Dashed blue: the circle the body sweeps turning in place round the + (its turning centre). Green band: the cut.
blind 41 cm30 cm tall
From the side. Dotted blue: the 3D lidar's lowest beam; anything 4 cm tall closer than that is unseen, so the stop field never shrinks below it.

Parts list

PartWhat it doesPriceSource
Body (3D-printed panels or a moulded shell)Weatherproof shell and blade guard≈ $60–120estimate
2 × geared DC motors with encodersDrive≈ $80estimate
Dual motor driverDrive≈ $30estimate
Small BLDC blade motor + ESC with brakingCutting≈ $60estimate
5S Li-ion pack with BMS (~75 Wh)Power≈ $90estimate
Raspberry Pi 5 8 GB + SSD + coolerThe brain≈ $215–245Raspberry Pi list price
simpleRTK2B GNSS + antennaCentimetre positioning≈ $235ArduSimple
BNO085 IMUHeading and tilt$30Adafruit
Livox Mid-360 3D lidarSeeing obstacles$979list price
Pico 2 + safety partsThe hardware blade interlock≈ $100estimate
Total≈ $1,879–1,969

Build plan

  1. Print and fit the shellBody panels and the blade guard; check the guard against hardware/safety.md.Test: A 10 cm probe can't reach the blade
  2. DriveMotors, driver, caster; wire the encoders.Test: Drives straight 5 m within 5 cm
  3. Brain and sensorsSame stack as the sim, with ROBOT=quark.Test: Smoke test passes on the real robot
  4. BladeBlade motor with braking; interlock first.Test: Blade stops within 2 s of the stop button